


We are pleased to announce that Ruijie Tang, a Ph.D. student in Prof. Hongliang Ren’s research group at The Chinese University of Hong Kong (CUHK), successfully defended his doctoral dissertation on October 28, 2026!
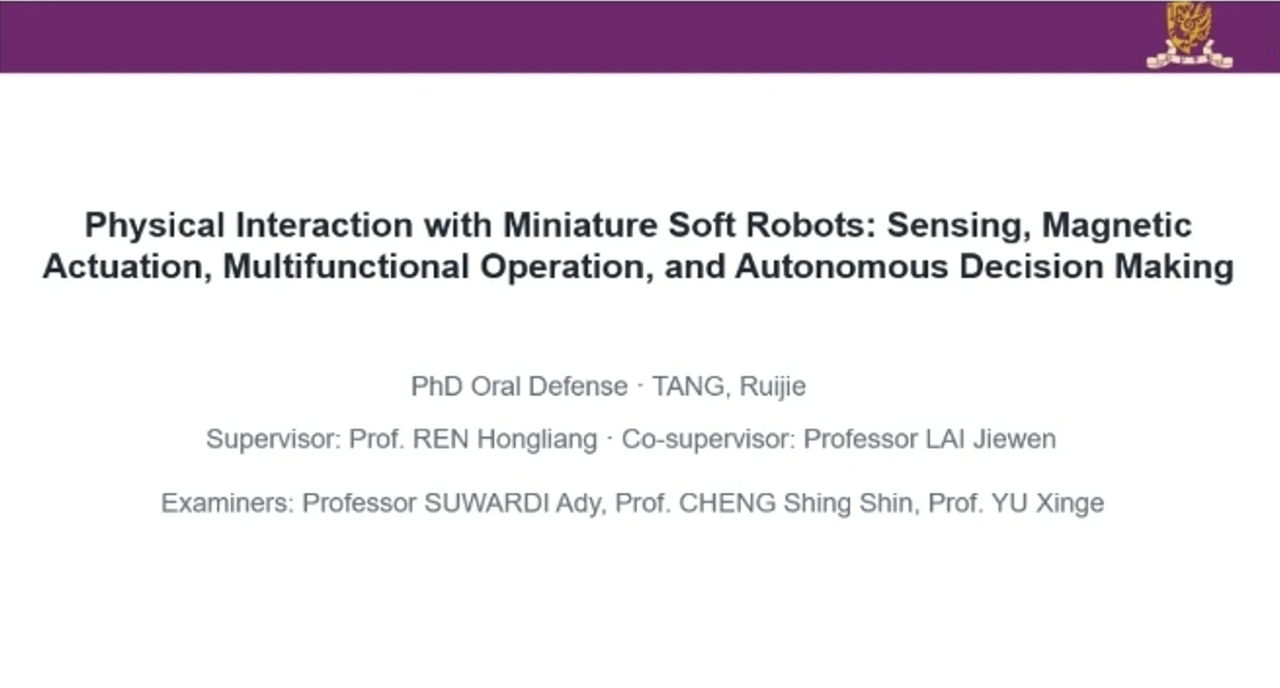
His doctoral dissertation, entitled “Physical Interaction with Miniature Soft Robots: Sensing, Magnetic Actuation, Multifunctional Operation, and Autonomous Decision Making,” focuses on enabling controllable physical interactions of miniature soft robots in constrained, compliant, and dynamically changing environments. The research primarily explores interaction force sensing for contact-state perception, magnetic actuation and resonance mechanisms for regulating robotic motion and physical functionalities, and the integration of active exploration with Vision-Language-Action (VLA) models to enable task-oriented autonomous decision-making.
The Ph.D. defense committee consisted of Prof. Hongliang Ren (CUHK), Prof. Ady Suwardi (CUHK), Prof. Jiewen Lai (CUHK), Prof. Xinge Yu (City University of Hong Kong), and Prof. Shing Shin Cheng (CUHK). We extend our sincere gratitude to the committee members for their insightful feedback and guidance.
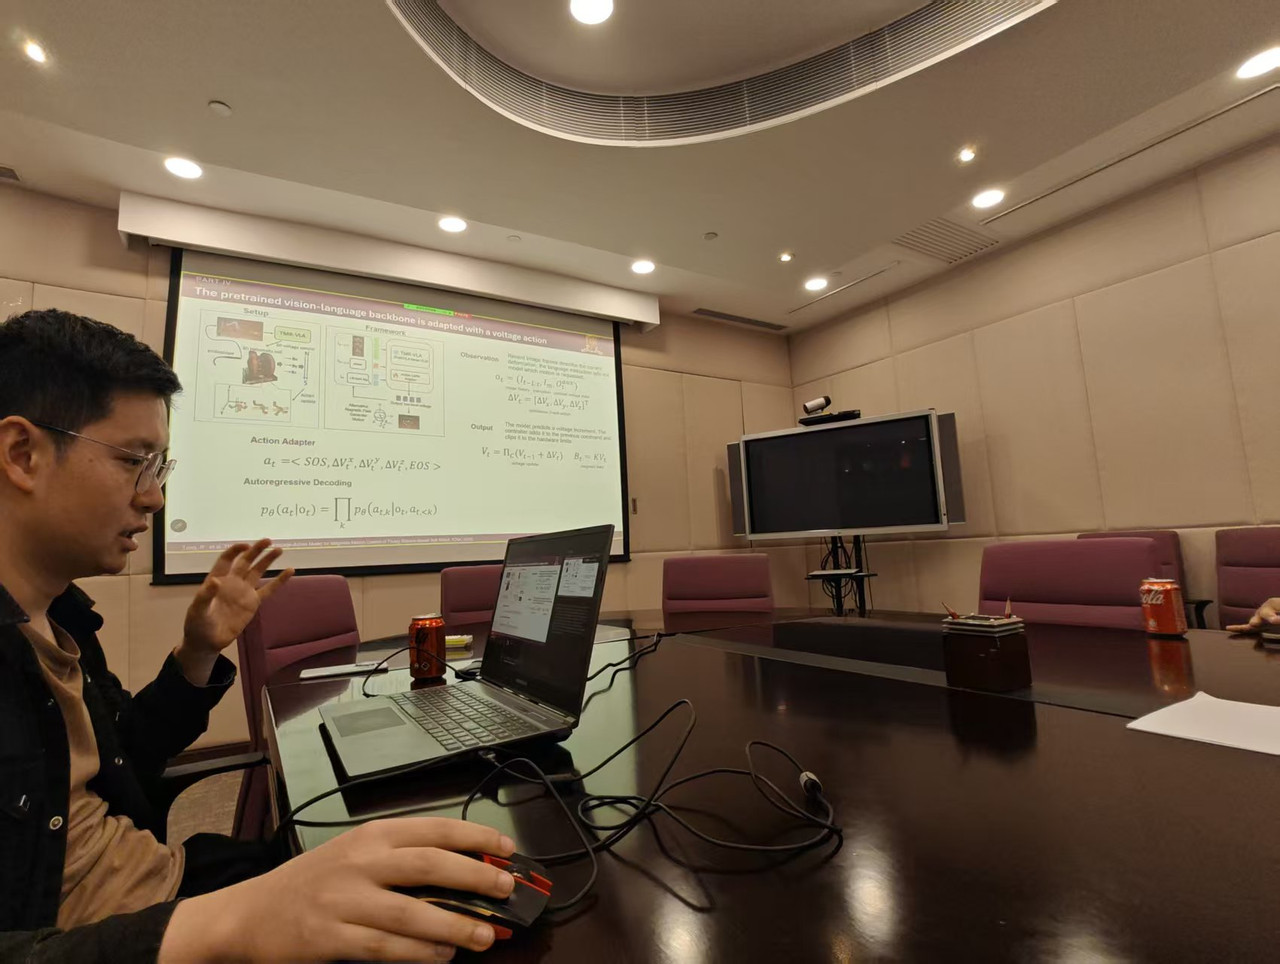
During his doctoral studies, Ruijie Tang conducted extensive research on interaction force sensing and temporal modeling, multimodal locomotion and structural design of magnetically actuated soft robots, resonance-frequency-selective multifunctional physical interactions, autonomous environmental exploration, and Vision-Language-Action (VLA)-based robotic control.
His research has resulted in publications in several internationally recognized robotics journals and conferences. Selected publications include:
[1] Tang, R., et al. “Data-Driven 3-D Tactile Cues with Intermediate Soft Interfaces Toward Training Needle Insertions.” IEEE Sensors Journal, 2023.
[2] Tang, R., et al. “A Frequency-Modulated Tripedal Soft Magnetic Robot With Diverse Motion Modalities for Ingestible Applications.” IEEE Robotics and Automation Letters, 2024.
[3] Yao, S.*, Tang, R.*, et al. “An RNN-LSTM Enhanced Compact and Affordable Micro Force Sensing System for Interventional Continuum Robots With Interchangeable End-Effector Instruments.” IEEE Transactions on Instrumentation and Measurement, 2023.
[4] Zhang, T.*, Tang, R.*, et al. “Kinetostatic Modeling and Comparative Dexterity Analysis of Telescoping Continuum Robots With Tendon-Magnetic Coactuation for Retrograde Endoluminal Navigation.” IEEE/ASME Transactions on Mechatronics, 2025.
[5] Tang, R., et al. “Kangaroo Combat-Inspired Magnetic Soft Robot with Tail Support for Multi-Modal Locomotion.” Procedia Computer Science, 271, 127–133, 2025 (ICBIR 2025).
[6] Tang, R., et al. “TMR-VLA: Vision-Language-Action Model for Magnetic Motion Control of Tri-leg Silicone-based Soft Robot.” IEEE International Conference on Robotics and Automation (ICRA), 2026.
* Equal contribution.
🎉 Congratulations once again to Ruijie Tang on this significant academic milestone! We wish him continued success in his future research and career endeavors! 🚀👏
