RENLab Visits The Third Affiliated Hospital of Sun Yat-sen University for Embodied Medical Robotics Academic Salon

On the afternoon of April 24, 2026, Professor Hongliang Ren’s research team from The Chinese University of Hong Kong visited The Third Affiliated Hospital of Sun Yat-sen University (SYSU Third Hospital) to hold an academic symposium and salon on Embodied Medical Robotics. The event was held in Conference Room 2006 of the Comprehensive Building, aiming to advance academic communication and potential research collaboration in medical robotics and intelligent healthcare.

The meeting was chaired by Dr. Liu Zifeng, Director of the Big Data and Artificial Intelligence Center of SYSU Third Hospital. Vice President Qintai Yang delivered a welcome speech, introducing the hospital’s clinical strengths and looking forward to close cooperation in medical robot research and translation.

Professor Hongliang Ren delivered a keynote report on minimally invasive flexible robotic systems and embodied intelligence in medicine. Members of his research team then presented recent advances in precision interventional tools, magnetic robotic systems, endoscopic intelligent navigation, autonomous surgical control, and medical image perception, showcasing the team’s innovative work in clinical-oriented medical robotics.
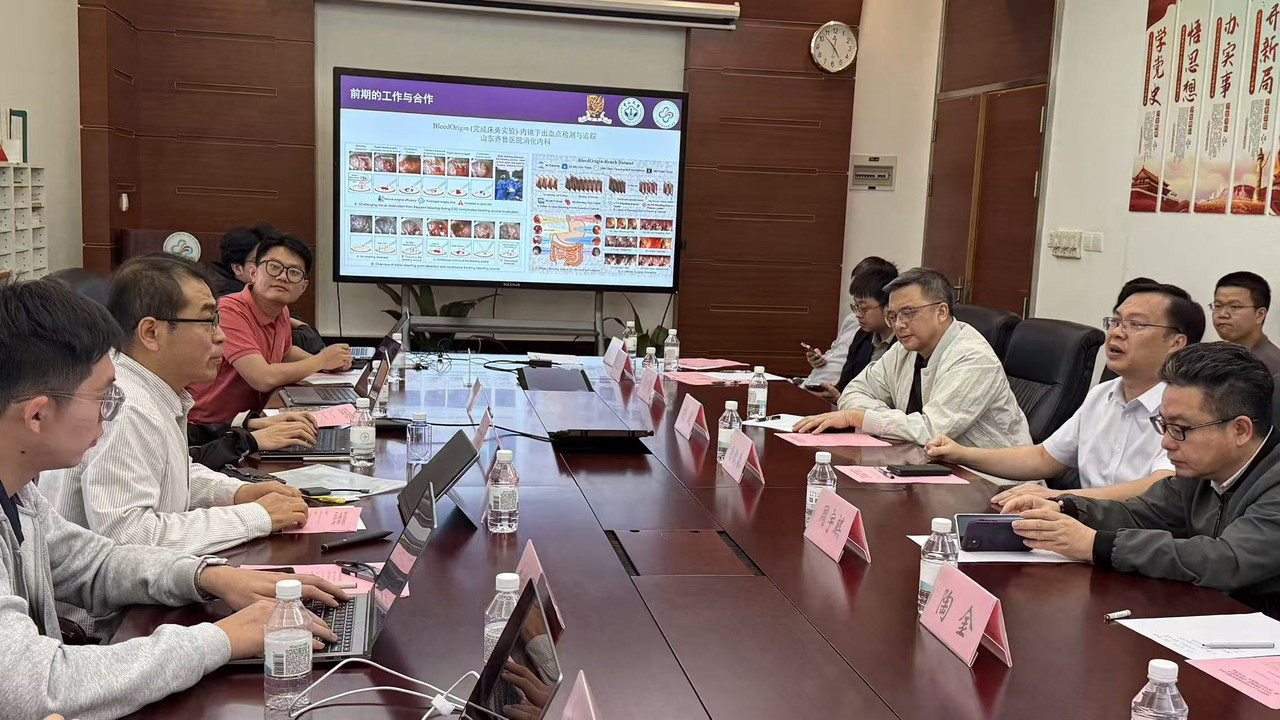
During the discussion session, clinicians and researchers from multiple departments of SYSU Third Hospital had in-depth exchanges on clinical demands, technical applications, and joint research plans. Both sides reached positive consensus on future cooperation in scientific research, talent development, and clinical translation.

At the end of the meeting, Vice President Qintai Yang delivered a concluding speech and spoke highly of this academic exchange. This symposium effectively bridged engineering research and clinical practice, and laid a solid foundation for the future development and application of embodied medical robotics.

About The Third Affiliated Hospital of Sun Yat-sen University

The Third Affiliated Hospital of Sun Yat-sen University was founded in 1971 and is a comprehensive Grade-A tertiary hospital directly administered by the National Health Commission of China. As a major clinical teaching base of Sun Yat-sen University, the hospital undertakes medical care, education, research, prevention, rehabilitation, and specialist training. It currently operates four campuses: Tianhe, Lingnan, Yuedong, and Zhaoqing. The hospital has developed distinctive strengths in liver disease, brain disorders, and immune-related diseases, supported by national key disciplines and national clinical key specialty programs. It is also recognized as a Guangdong High-level Hospital and serves as an output hospital for the development of national regional medical centers.
🚀 NVIDIA GTC 2026: Open-H-Embodiment — The World’s First and Largest Open-Source Medical Robotics Dataset

Thrilled to share our latest international collaboration! At NVIDIA GTC 2026 in San Jose, CA, the team led by Professor Hongliang Ren from The Chinese University of Hong Kong (CUHK), in partnership with NVIDIA and 35 leading global institutions, officially released Open-H-Embodiment, the world’s first and largest open-source dataset for medical robotics, now available on HuggingFace.

During the GTC keynote, Kimberly Powell, NVIDIA’s VP of Healthcare, highlighted this milestone. Our lab is honored to be a primary contributor, filling the critical gap in Embodied AI for medical robotics by providing high-fidelity data for contact dynamics and closed-loop control.

🧠✨ What we contributed & developed:

This project breaks the “perception-heavy, execution-light” limitation of traditional medical AI. Key highlights include:

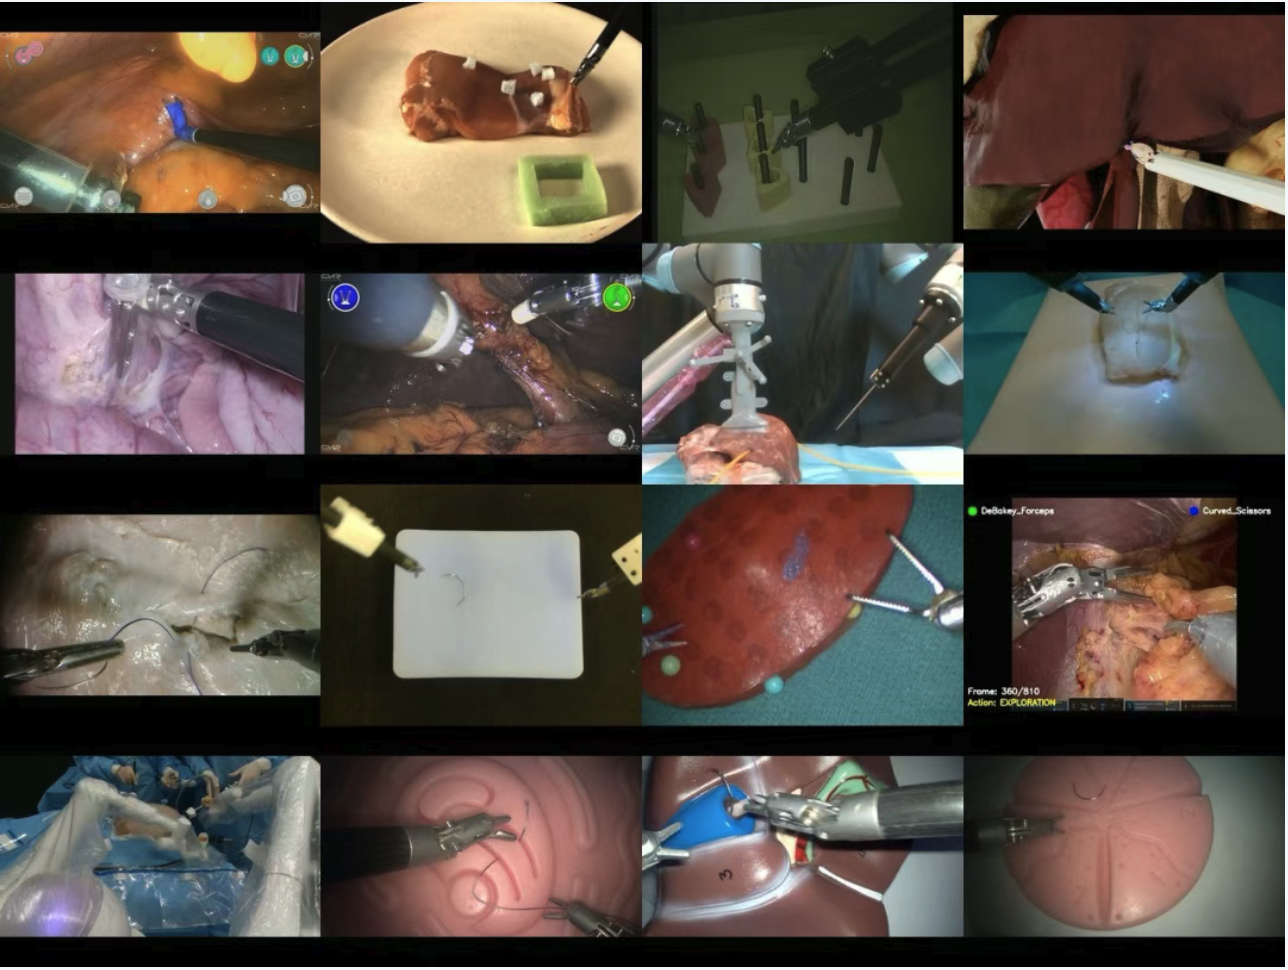
🔹 778 Hours of Massive Multimodal Data: The dataset covers 400 complete clinical surgeries and 9 major robotic platforms (e.g., dVRK, CMR Versius, Kuka). It includes 65% clinical data, 23% bench-top experiments, and 12% simulation data.

🔹 Three High-Value Specialized Datasets from Our Lab:

  • Dual-Source Ultrasound Dataset: Experts-level trajectories covering in-vivo porcine EUS and human forearm scanning, overcoming complex organ environments and multi-device calibration.
  • Robotic Surgery Skill Dataset: Multi-modal data (RGB/RGB-D + Kinematics) for tissue manipulation and suturing, featuring millisecond-level synchronization and dual-mode control (teleoperation & automation).
  • Flexible Endoscope Tracking Baseline: A standardized dataset addressing hysteresis and deformation in flexible endoscopy, supporting nanosecond-level time synchronization.

🔹 Surgical VLA & World Models:

  • GR00T-H: A 3B-parameter Vision-Language-Action model based on NVIDIA Isaac GR00T, capable of long-horizon dexterous tasks like end-to-end suturing.
  • Cosmos-H-Surgical-Simulator: An action-conditioned world model that boosts simulation efficiency by over 70x, bridging the sim-to-real gap.

🎯 Key Results: ✅ Global Standardization: First effort to unify medical robotic data across different devices and institutions under CC-BY-4.0. ✅ Efficiency Boost: Accelerated surgical simulation (600 sims in 40 mins) to generate high-fidelity video-action pairs. ✅ Clinical Relevance: Successfully captured nearly 500 hours of real-world clinical data for hernia, gallbladder, and uterine surgeries.

💡 Why it matters: This initiative provides the foundational “bedrock” for Medical Physical AI. By sharing high-quality, synchronized data for surgery, ultrasound, and endoscopy, we are lowering the barrier for researchers worldwide to develop autonomous surgical agents that are both explainable and adaptive.

🌱 What’s next? Our lab is continuing to deepen research in: 🔹 Reasoning-based autonomous control for surgical robots. 🔹 Cross-platform generalization of Medical VLA models. 🔹 Clinical translation of Embodied AI to improve patient outcomes.

Datasets address: https://huggingface.co/datasets/nvidia/PhysicalAI-Robotics-Open-H-Embodiment

Project website: https://github.com/open-h

#NVIDIAGTC2026 #MedicalRobotics #EmbodiedAI #HuggingFace #CUHK #OpenSource #HealthcareInnovation