Month: March 2015
A Three-Dimensional-Printed Home-Based Flexible Nasopharyngeal Explorer With Diamond Cuts
A Novel Tele-Operated Flexible Robot Targeted for Minimally Invasive Robotic Surgery
Abstract
In this paper, a novel flexible robot system with a constrained tendon-driven serpentine manipulator (CTSM) is presented. The CTSM gives the robot a larger workspace, more dexterous manipulation, and controllable stiffness compared with the da Vinci surgical robot and traditional flexible robots. The robot is tele-operated using the Novint Falcon haptic device. Two control modes are implemented, direct mapping and incremental mode. In each mode, the robot can be manipulated using either the highest stiffness scheme or the minimal movement scheme. The advantages of the CTSM are shown by simulation and experimental results.
A Novel Tele-Operated Flexible Robot… (PDF Download Available). Available from: https://www.researchgate.net/publication/281389458_A_Novel_Tele-Operated_Flexible_Robot_Targeted_for_Minimally_Invasive_Robotic_Surgery [accessed May 30 2018].
full text
3 Comments
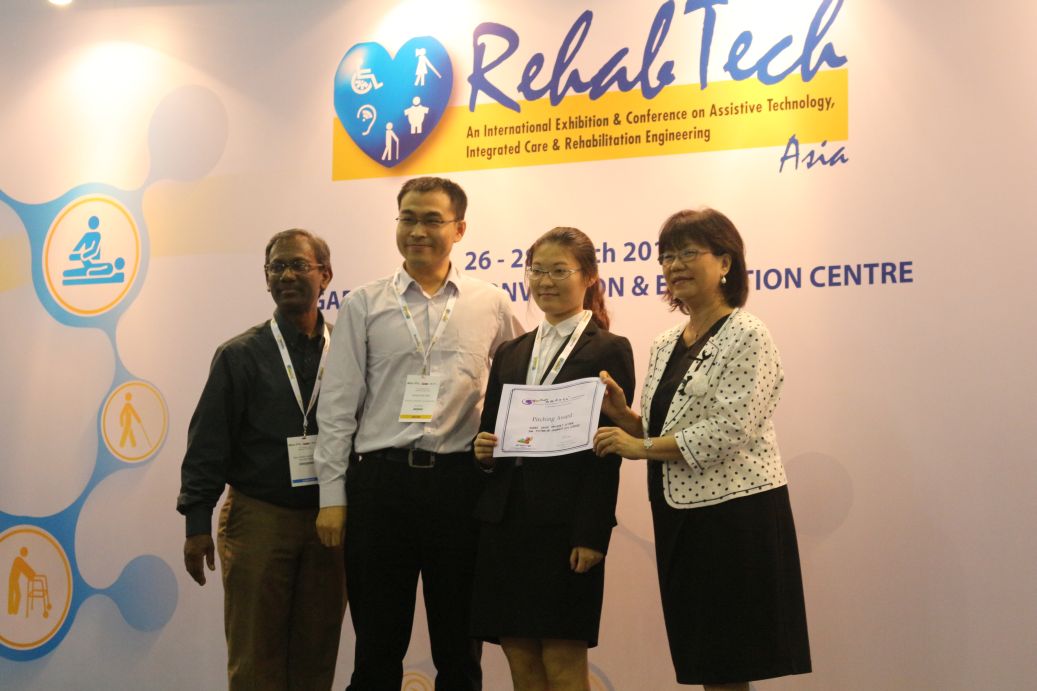
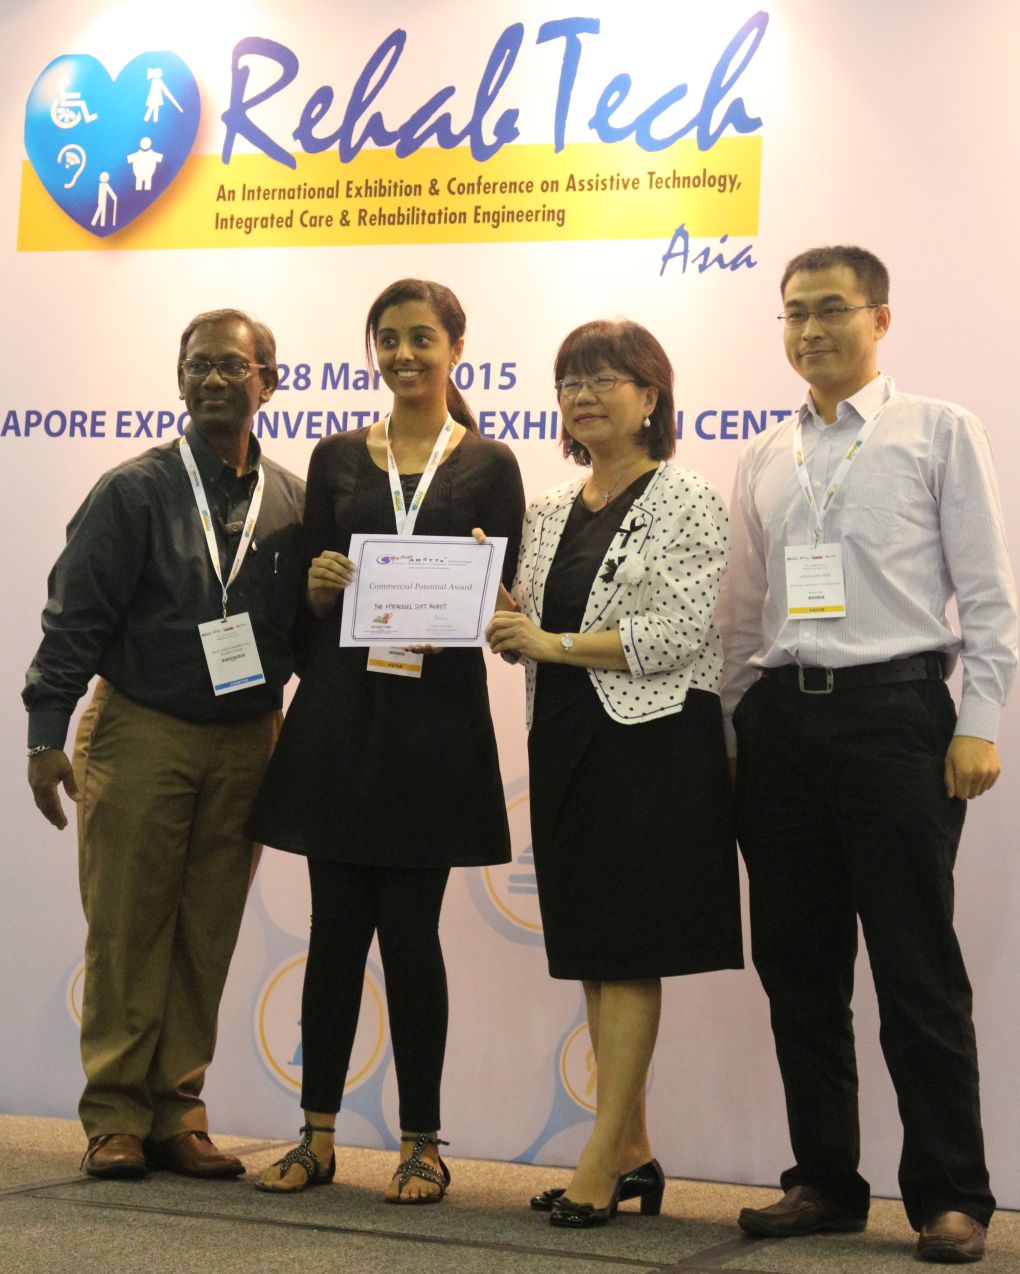
Two projects won awards from Asia Pac AR&TTs challenge 2015
(Mar, 2015) In the recent Asia Pac AR&TTs challenge 2015, our project on a soft robotic system for oral intervention (team members: Neera, Yi, Hongliang) won the Commercial Potential Award and the project on magnetic actuated robotic intervention (team members: Shen Shen, Zhu Jingling, Song Shuang, Li Jun, Loh Kai Ting, Ren Hongliang) won the Pitching Award.