Surgical Manipulator based on Parallel Mechanism

Abstract

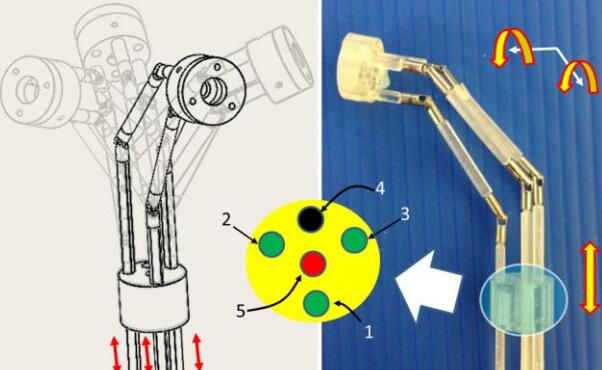
We presents a 5-DOF manipulator which consists of three parts, 1-DOF translational joint, a bendable skeleton (2-DOF for Omni-directional bending motion), and a rotatable forceps gripper (1-DOF for rotation, 1-DOF for opening/closing). The bendable segment in the manipulator achieves two orthogonal bending DOFs by pulling or pushing three parallel universal-joint-based shaft chains. Forward and inverse kinematics of the bendable skeleton is analyzed. The workspace calculation illustrates that the structure of the three parallel shaft chains can reach a bending angle of 90 degree in arbitrarily direction. The reachability of the manipulator is simulated in Adams. According to the surgical requirements, the manipulator is actuated to draw circle during the tests while the end effector is kept bending at 60 degree. The results show that the end effector can precisely track the planning trajectory (precision within 1 mm).
Video demo

Publications

Q. Liu; J. CHEN; S. Shen; B. Zhang; M. G. Fujie; C. M. Lim & H. REN Design, Kinematics, Simulation of Omni-directional Bending Reachability for a Parallel Structure Forceps Manipulator BioRob2016, 6th IEEE RAS/EMBS International Conference on Biomedical Robotics and Biomechatronics, June 26-29, 2016, Singapore, 201

A Novel 4-DOF Hybrid Magnetic Bearing for DGMSCMG

Abstract
In this paper, a novel structure of four degrees of freedom (4DOF) hybrid magnetic bearing is proposed for double gimbal magnetically suspended control momentum gyro (DGMSCMG). It includes two active parts and one passive part, and every active part has eight stator magnetic poles around the circumference in X and Y directions, which are divided into upper and lower layers. The passive part has two whole magnetic rings, which is located in the middle of this 4DOF hybrid magnetic bearing. The radial active force is analyzed by equivalent magnetic circuit method (EMCM) and the axial resilience force is analyzed by the infinitesimal method based on the end magnetic flux. Meanwhile, 3-D finite element model of the 4DOF hybrid magnetic bearing is establish with ANSYS software, and the radial displacement versus radial force, the current versus radial force, and the axial displacement versus axial resilience force characteristics are analyzed compared with the EMCM. Furthermore, the 10Nms DGMSCMG prototype with proposed 4DOF hybrid magnetic bearing is manufactured, and the experiments of the radial active force test and the axial resilience force test are carried out. Experimental results show that the presented 4DOF hybrid magnetic bearing has good force performance and verify the correctness of the theoretical analysis.
More Information: