A High-Sensitivity Fiber Bragg Grating Displacement Sensor Based on Transverse Property of a Tensioned Optical Fiber Configuration and Its Dynamic Performance Improvement

Abstract:

This paper presents a high-sensitivity fiber Bragg grating (FBG) displacement sensor with a novel configuration for structural health monitoring. The transverse movement of an optical fiber that has been configured as a tight suspension status with its two ends fixed has been utilized to measure displacement. The theoretical models for both static and dynamic displacements have been derived. The corresponding simulations have been conducted to determine the relationship between the model parameters and the sensor performance. This approach supports the sensor design improvement and structural optimization. Two small working ranges have been selected to determine the simplified linear model according to Taylor series. The sensitivity of this sensor can reach up to 490.1 pm/mm with a high resolution of 2.04 ฮผ m in a range of 1.4~2.0 mm. The introduction of the supporting spring unit has significantly enhanced the sensorโ€™s resonant frequency without sacrificing the sensitivity. The application of the stiffer spring unit has enlarged the working bandwidth from 0~8 Hz to exceed 50 Hz. Enhancing the damping ratio unit can effectively improve the flatness of the dynamic response within the working bandwidth, while it does not affect other dynamic properties of the sensor. These improvements and design guidelines have been validated by both dynamic experiments and theoretical modelling.
More Information:

Full Text

Development of flexible fabric based tactile sensor for closed loop control of soft robotic actuator

Abstract:

The ability to sense and measure object properties based on touch is known as tactile sensing. The flexibility and dexterity of soft robots can be fully explored, only with efficient tactile feedback from the environment or the objects the robot interact with. This paper discusses about the development of a soft fabric based piezoresistive tactile sensor, the related calibration experiments and procedures. Fabric based sensors are flexible, stretchable and can confer to both hard and soft
surfaces easily. The ability of the tactile sensor to enhance the efficiency of robotic activities is demonstrated in a simple cutting task. The robotic end effector used is a pneumatically controlled soft gripper. Experimental results show that the feedback from the tactile sensor developed is successfully used to detect the completion of the cutting tas

More Information:

Full Text

Soft tactile sensors presented at CASE 2017

CASE_2017_Presentation

DEVELOPMENT OF FLEXIBLE FABRIC BASED TACTILE SENSOR FOR CLOSED LOOP CONTROL OF SOFT ROBOTIC ACTUATOR


 Godwin Ponraj, Senthil Kumar Kirthika, Nitish V. Thakor, Fellow, IEEE, Chen-Hua Yeow, Member, IEEE, Sunil L. Kukreja, Senior Member, IEEE and Hongliang Renโ€ , Member, IEEE


Abstractโ€” The ability to sense and measure object properties based on touch is known as tactile sensing. The flexibility and dexterity of soft robots can be fully explored, only with efficient tactile feedback from the environment or the objects the robot interact with. This paper discusses about the development of a soft fabric based piezoresistive tactile sensor, the related calibration experiments and procedures. Fabric based sensors are flexible, stretchable and can confer to both hard and soft surfaces easily. The ability of the tactile sensor to enhance the efficiency of robotic activities is demonstrated in a simple cutting task. The robotic end effector used is a pneumatically controlled soft gripper. Experimental results show that the feedback from the tactile sensor developed is successfully used to detect the completion of the cutting task.

Index Terms โ€“ Fabric force sensor, Piezoresistive sensor, Soft robotic finger, Tactile feedback, Closed loop control.

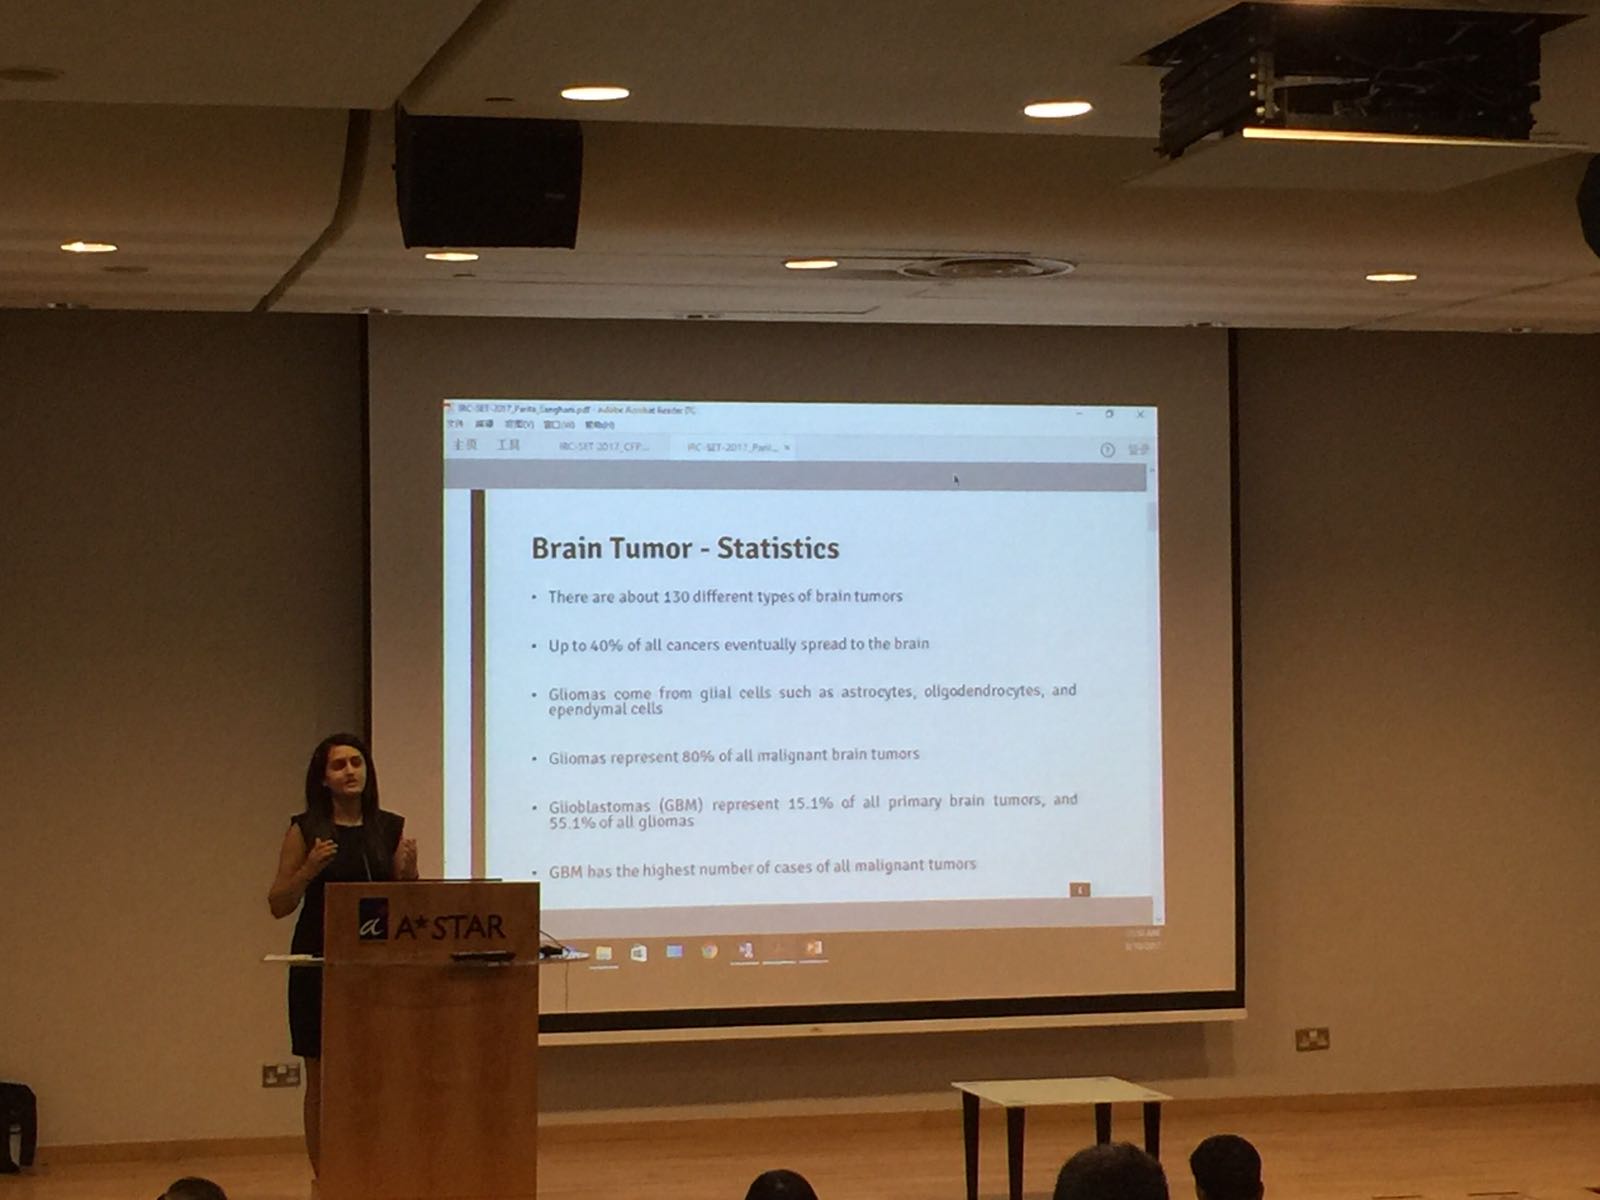
Team attending IRC-SET 2017


Our team attended IRC-SET 2017 and presented

  • Semi-Automated Segmentation of Glioblastomas in Brain MRI Using Machine Learning Techniques by Naomi Joseph, Parita Sanghani, Hongliang Ren
  • Air-Powered Soft Robotic Gripper Using Lego Bricks and Jamming of Granular Material: An Initial Approach by Hritwick Banerjee Li Ting Hongliang Ren

WhatsApp Image 2017-08-10 at 2.01.53 PM